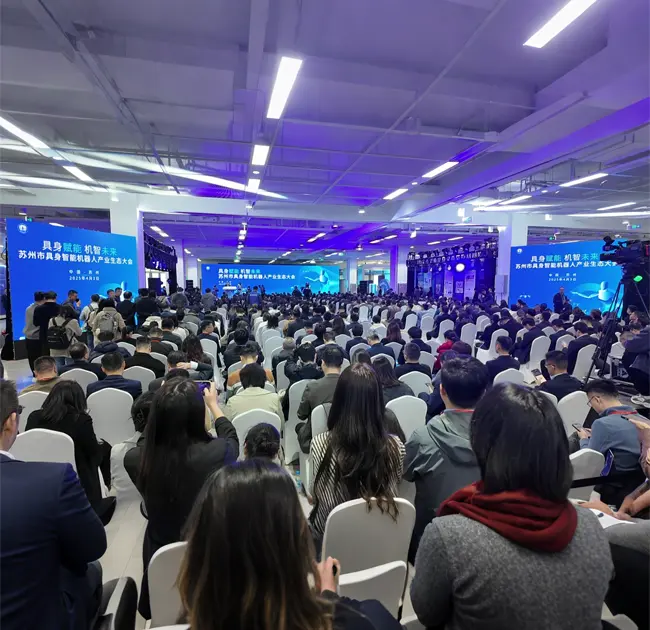
SEAMOTION showcased 6 types of joint modules, drivers and encoder products at the World Robot Conference (WRC).
We presented four harmonic joint modules with outer diameters of 70 mm, 80 mm, 90 mm and 110 mm, alongside two star joint modules specially developed for quadruped robots, as well as dedicated drivers for joint modules and inductive encoders.
Many competitors develop joint modules starting from mechanical structures. We take a different approach.
SEA MOTION’s first competitive advantage lies in its drivers.
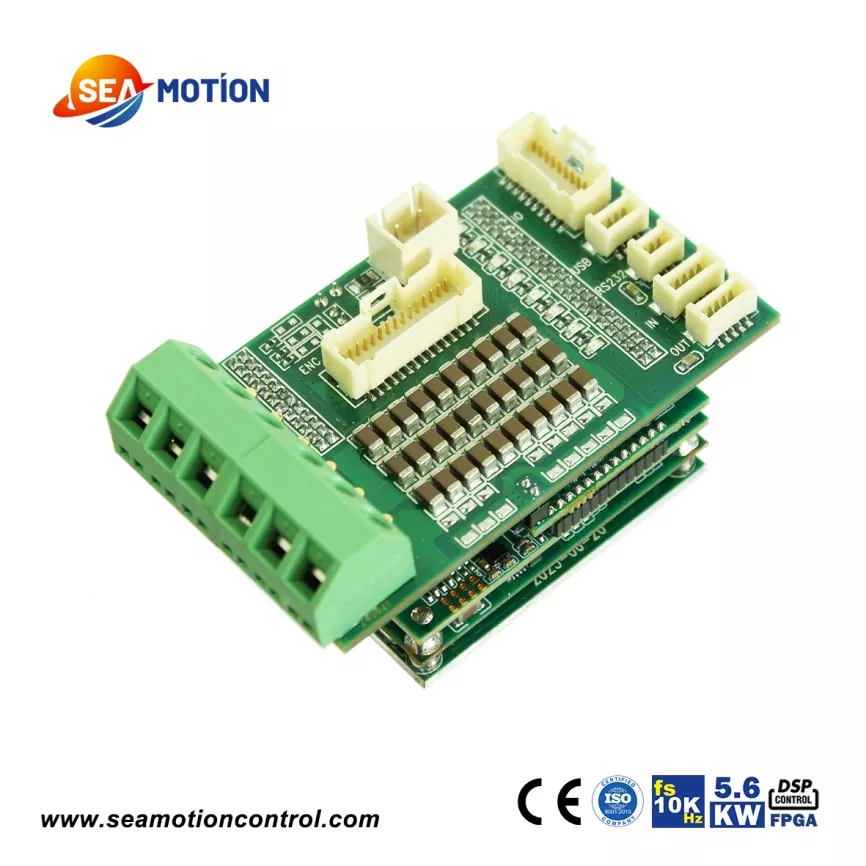
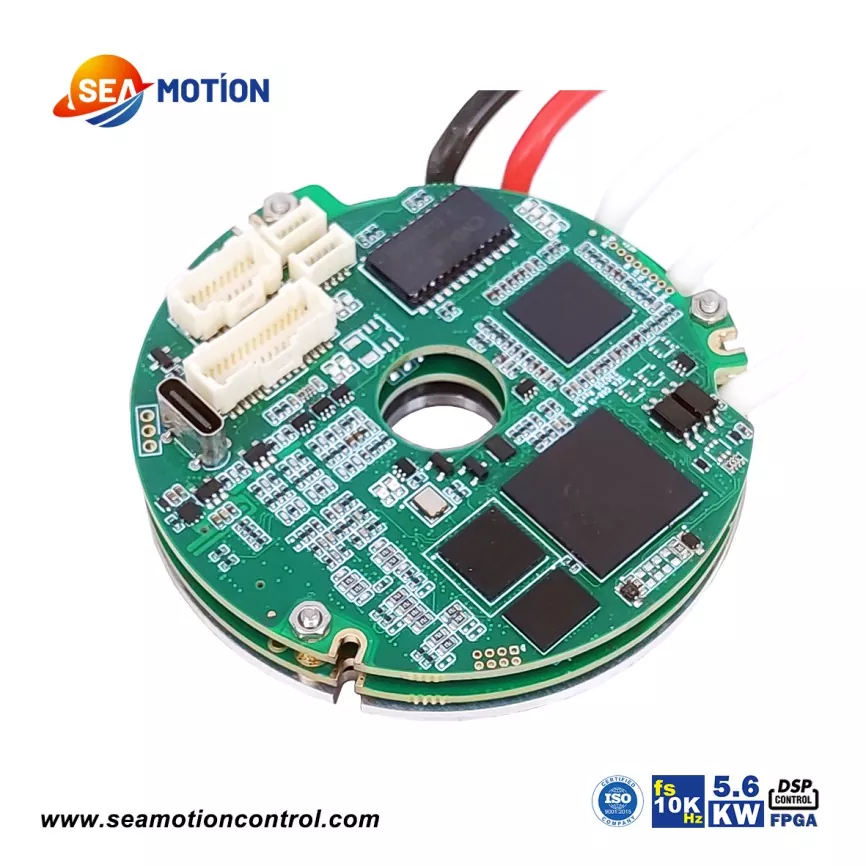
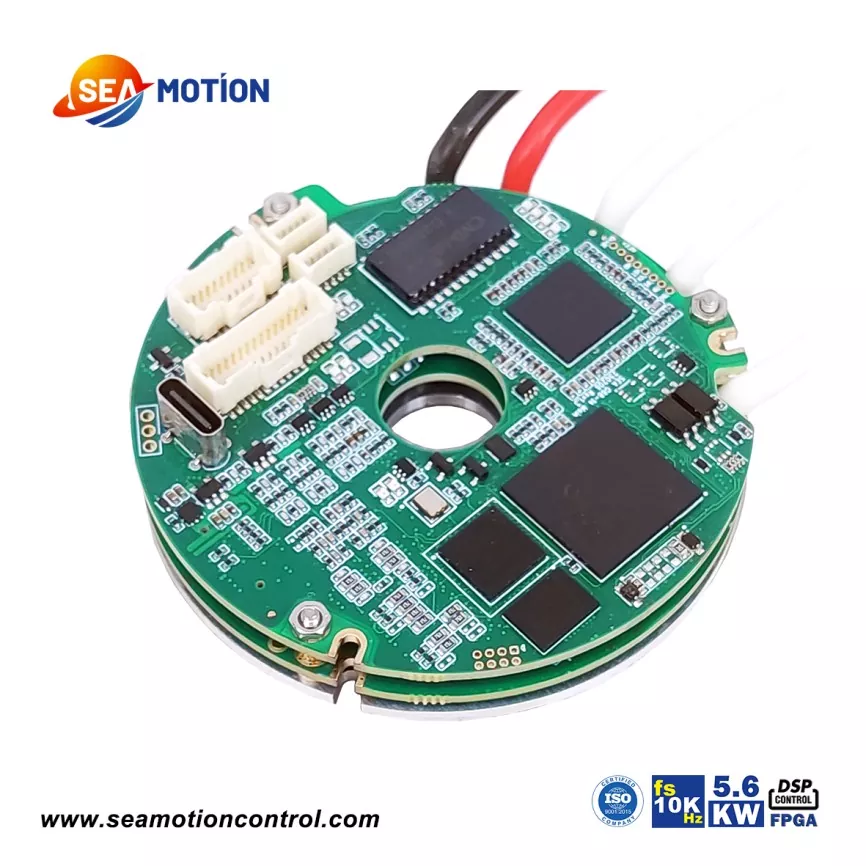
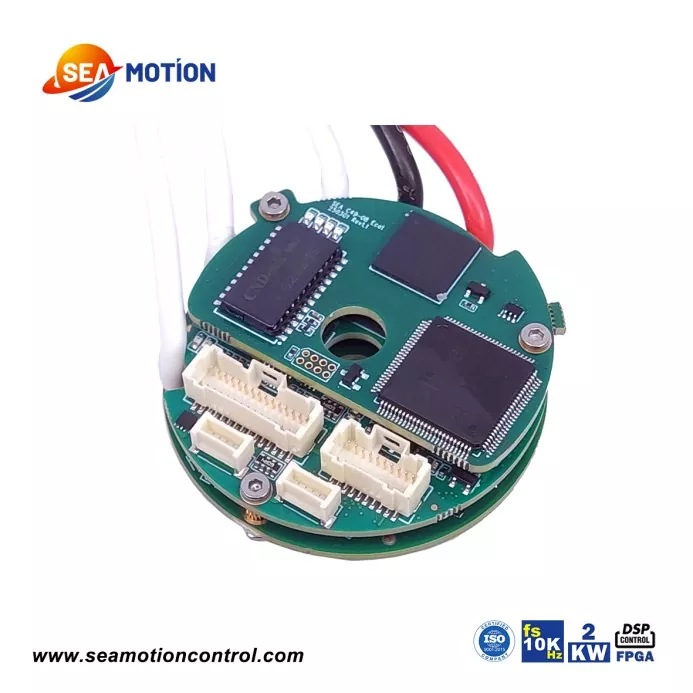
With years of in-depth expertise in driver development, we have launched a single-board driver optimized specifically for joint modules. It features smaller size, higher integration and more precise control.
To put it simply: other manufacturers “build the body first and then fit the brain”, while we “build a powerful brain and then design the body around it”.
What benefits does this “driver-oriented design philosophy” bring?
· Faster response: integrated drive-control architecture delivers low signal latency
· Less heat generation: high efficiency ensures stable long-term operation
· Easier commissioning: well-matched parameters enable plug-and-play deployment
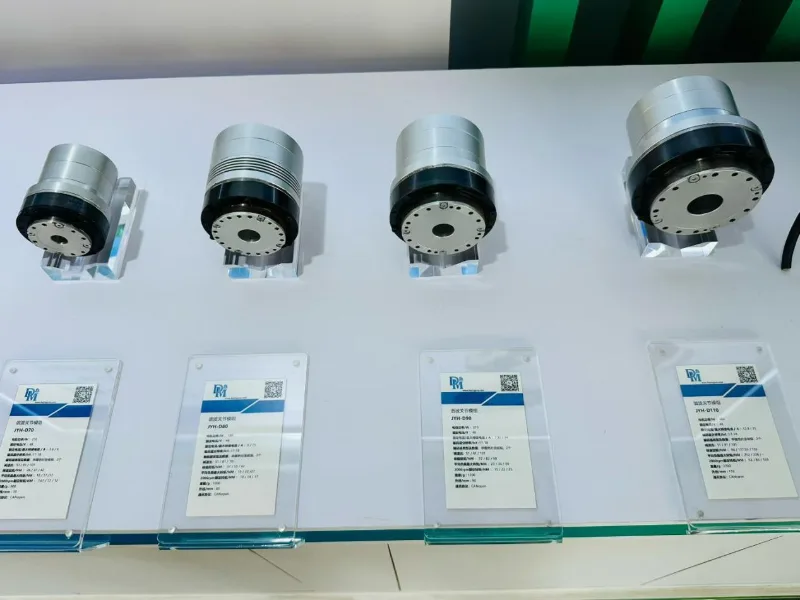
Our four harmonic modules (70/80/90/110 mm) all adopt a large hollow-shaft design.
What is the value of a large hollow shaft? Here is an analogy: A conventional joint resembles a solid pipe, forcing cables to run externally. This occupies extra space and causes accelerated cable wear. By contrast, our hollow-shaft joints allow cables to pass through the central bore.
Practical advantages include:
· Neat cabling: internal cable routing delivers a clean appearance
· Reduced friction: minimized cable bending extends service life
· Compact mechanical layout: well-suited for multi-joint serial configurations
This design achieves a streamlined overall structure and simplifies maintenance, especially for collaborative robots and quadruped robots.
SEA MOTION guarantees reliable quality thanks to an enterprise-grade supply-chain system.
Core components including harmonic reducers, bearings and encoders are sourced from leading industry suppliers after strict screening and long-term validation.
In short: every component you receive is backed by proven top-tier industrial technology.
The exhibition showpieces are two joint modules purpose-built for quadruped robots.
400 Nm Peak-Torque Planetary Joint Module
Application scenarios: large-size quadruped robots, load-carrying working quadruped robots Key specifications: 400 Nm peak torque for high power output Ingress protection: IP67 (dust-proof and water-proof, operable in rainy and muddy environments)
60 Nm Peak-Torque Light-Weight Joint Module
Application scenarios: medium-and-small-size quadruped robots, educational and research platforms Key specifications: 60 Nm peak torque with light weight and high agility Ingress protection: IP67 rated as well
Why emphasize IP67? Quadruped robots are no longer limited to laboratory floors. They are deployed for outdoor inspection, emergency rescue, agricultural plant-protection and other real-world settings where water, mud and dust are commonplace. Our joints can function normally even when submerged in water.
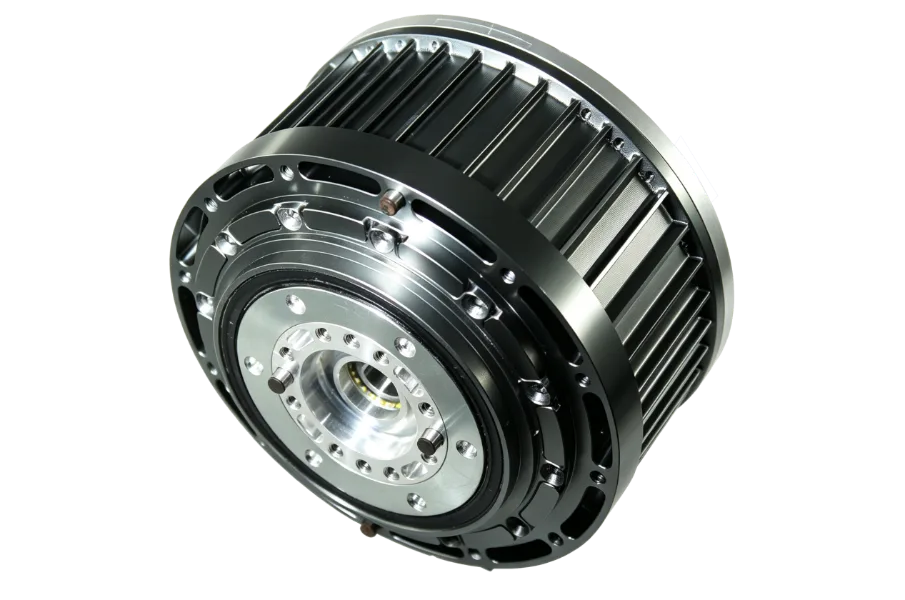
400 Nm Peak-Torque Planetary Joint Module
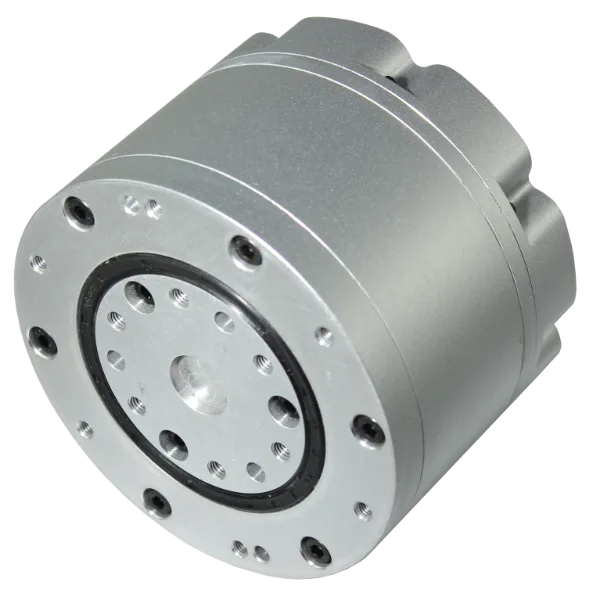
60 Nm Peak-Torque Light-Weight Joint Module